Robot Motion Studio
Design, simulate, and export PWM servo motion sequences for Arduino robots
Episodes & demos
- S01E01 Playhttps://jpeckenpaugh.github.io/robot-motion-studio/ ► Watch (opens in a new tab)
About
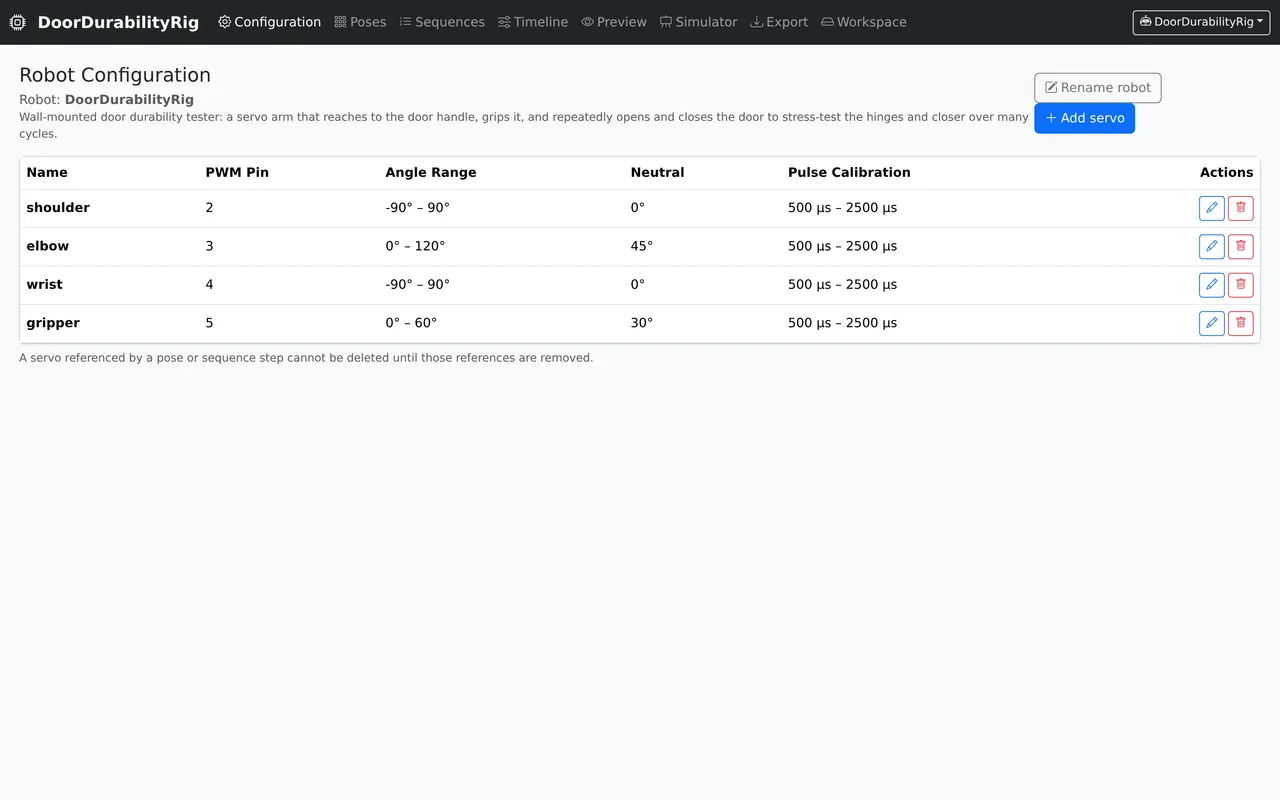
Robot Motion Studio (Robot Servo Sequence Designer) is a local, single-user multi-robot motion designer for PWM servo robots. Users configure servo motors (PWM pin, angle limits, neutral angle, pulse calibration), create reusable poses, author ordered/timed motion sequences through a visual timeline editor (add/reorder/edit/duplicate steps, play/pause/scrub, per-step speed and easing), inspect resolved motion in a preview, watch it in a dependency-free browser Canvas simulator, and export robot-scoped JSON (schema_version 2) for Arduino firmware or other robot-control software. Motion timing supports easing curves, finite/forever sequence repeat, and contiguous step-group loops. A fresh database seeds a door-durability-tester rig (shoulder/elbow/wrist/gripper servos) plus demo robots: PickPlaceArm (6-DOF arm), QuadTrotter (quadruped), BipedWalker (biped), and GimbalCam (pan/tilt). The original edition pairs a FastAPI + SQLite backend with a static Bootstrap 5 SPA (no build toolchain); a browser-only edition replaces the backend with sql.js WebAssembly SQLite running in a Web Worker and OPFS persistence, making it fully static for GitHub Pages. It is a proof-of-concept and does not communicate with physical Arduino hardware or perform real-time control.
Summary
A web app for designing and managing PWM servo motor control sequences for Arduino-based robots, with configuration, reusable poses, a timeline editor, a Canvas simulator, and structured JSON export.
Tech
- JavaScript
- Python
- FastAPI
- SQLite
- Bootstrap 5
- sql.js
- WebAssembly
- HTML/CSS
Tags
- arduino
- motion-sequencing
- robotics
- servo
- web-app